
Rover Architecture
Explore the technical engineering, precision mechanics, and autonomous AI systems powering Team Ogrodoot's flagship Martian exploration rover.
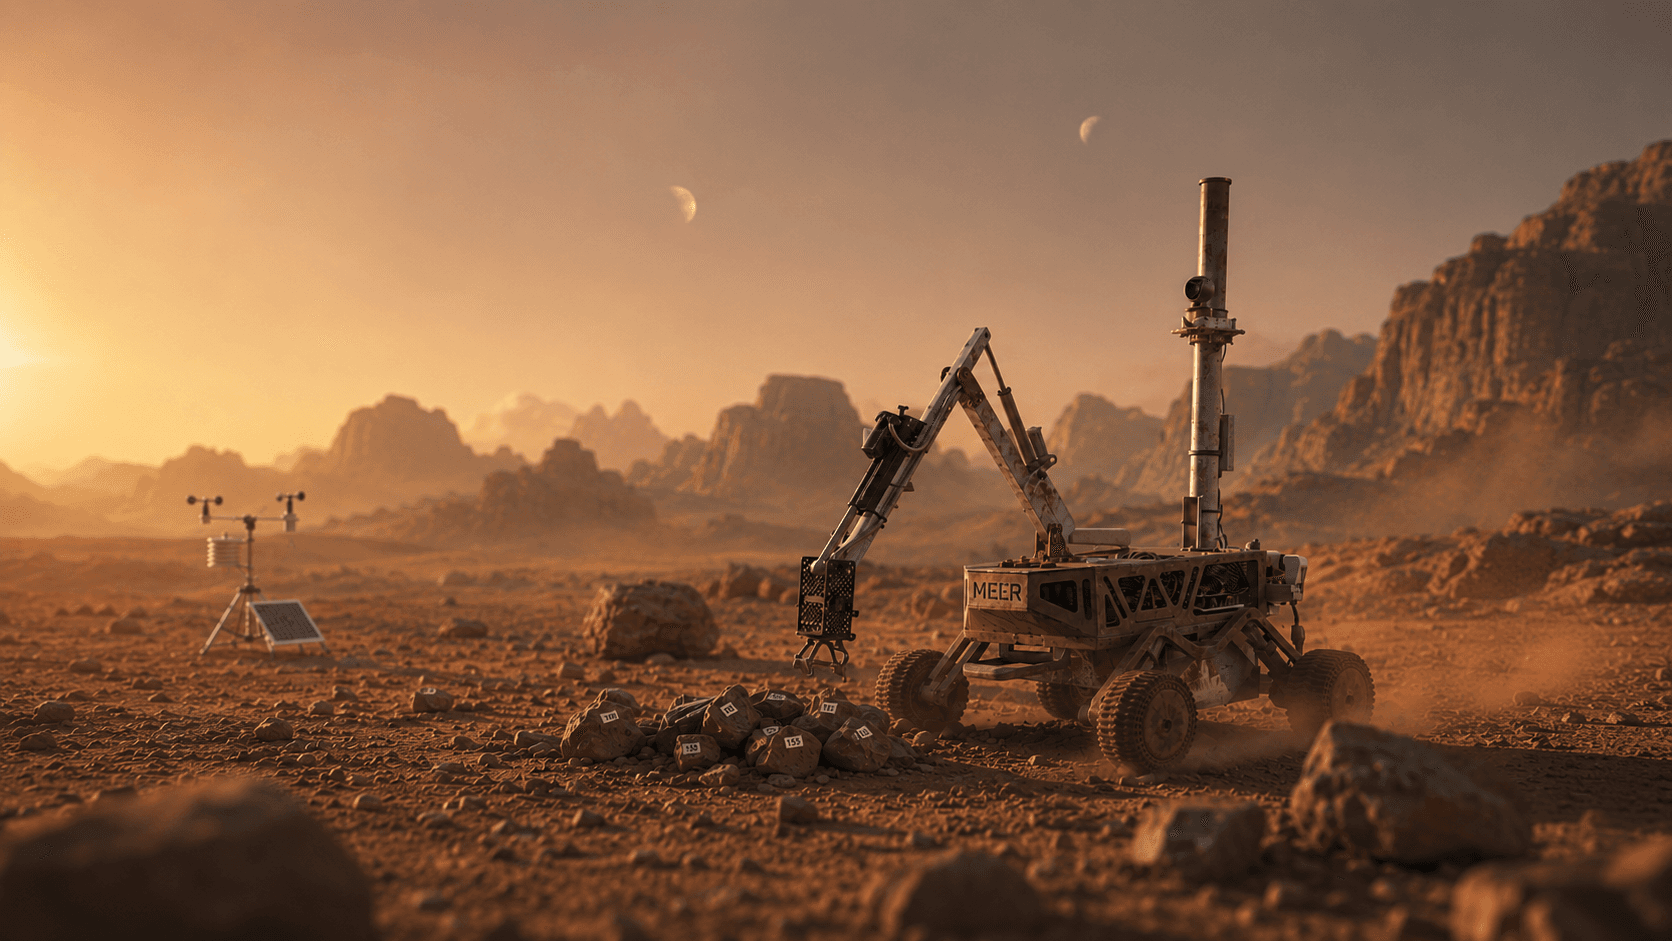
Ogrodoot MK-IV
Subsystem Breakdowns
Engineered with extreme reliability, modular maintenance, and analog Martian field durability.
Chassis & Mobility Architecture
6-wheel rocker-bogie suspension system constructed with aerospace-grade anodized aluminum. Equipped with custom high-torque planetary gear motors and compliant polyurethane tread wheels designed to surmount 35° inclines and 25cm obstacles without tipping.
6-DOF Robotic Manipulator
High-precision 6 degrees-of-freedom robotic arm capable of lifting a 5kg payload at full extension. Features custom cycloidal gearboxes, closed-loop magnetic encoder feedback, and quick-disconnect tool changers for diverse servicing tasks.
Autonomous Navigation Stack
Powered by ROS2 running on NVIDIA Jetson Orin edge computing. Leverages dual Intel RealSense depth cameras, 3D LiDAR point cloud processing, RTK-GPS positioning, and obstacle avoidance algorithms for autonomous GNSS waypoint navigation.
Onboard Astrobiology Science Lab
Automated subsurface soil sampling carousel with hermetically sealed sample containers. Onboard UV-Vis spectrometry and biochemical reagent assays perform in-situ detection of biomarkers, amino acids, and soil moisture profiling.
Long-Range Telemetry & Comms
Dual-band communication system with 5.8 GHz high-bandwidth video stream transmission and redundant 900 MHz long-range telemetry link. Utilizes active tracking directional patch antennas for reliable 9km non-line-of-sight connectivity.
Intelligent Power Matrix
Dual high-discharge 24V 20Ah LiPo battery banks monitored by custom microcontroller-managed BMS with per-cell voltage protection, thermal throttling, current sensors, and high-efficiency synchronous buck-boost regulators.
Interested in Technical Partnerships?
Collaborate with our engineering team on robotics hardware, sensor integrations, or research sponsorship.